Robotics Software Engineer · Austin, TX

Jerrar Bukhari

Perception · Simulation · Embedded Systems

I build the eyes, brains, and test harnesses of autonomous robots. Over 7 years I've shipped three generations of 6-DoF pallet pose detection, led a high-fidelity Isaac Sim initiative, and deployed 150+ perception-enabled AMRs across 30 warehouses — backed by 2 granted US patents.

  • LocationAustin, TX · Open to relocation
  • Experience7+ years in robotics
  • StatusOpen to full-time roles

01 About

I got into robotics because I wanted to build things that move — and then I got hooked on the harder question underneath: how does a machine know where it is and what it's looking at? That question has kept me busy for the better part of a decade.

Most of that time was spent at AutoGuide Mobile Robots, where I started as a controls engineer and gradually drifted toward the messy, fascinating problem of perception. I ended up owning the perception and simulation stack for a fleet of warehouse robots and forklifts — which in practice meant a lot of time in a warehouse at odd hours, pointing cameras at pallets, and a lot of time in simulation trying to make the real world behave the way the model said it should.

The work I'm proudest of isn't a single algorithm. It's that the systems I built ended up in the field — 150+ robots across 30 warehouses — and that the simulation work caught problems before a customer ever saw them. I like shipping things that have to work when nobody's watching.

Outside of work, I spent four years leading the software team for the Guardian LF1, a volunteer-built underwater robot that hunts invasive lionfish. We were the first to catch one autonomously, which was surreal — and it's still the project I bring up when someone asks why robotics is worth the trouble.

Right now I'm back from a year of travel and looking for my next team. If you're building robots that have to perceive the real world, I'd love to talk.

jerrar@robot:~
$ whoami
jerrar — robotics engineer, Austin TX
M.Eng Robotics, University of Maryland

$ cat how_i_work.txt
• prototype fast, then measure everything
• if it only works in sim, it doesn't work
• the field is the only test that counts
• write the docs your teammate will need

$ ls ~/current_focus
perception/   simulation/   embedded/
(open to full-time roles)

$ echo $WHY
because a robot that sees the world
correctly can do work that's boring,
dangerous, or impossible for people

02 Experience

Robotics Software Engineer — Perception & Simulation

AutoGuide Mobile Robots · acquired by Mobile Industrial Robots (Teradyne) — North Reading, MA

Feb 2021 – Nov 2025

Perception

  • Architected and shipped three successive generations of 6-DoF pallet pose detection over 4 years — 2D LiDAR, 3D time-of-flight camera, and RGB machine-learning techniques — with 2 granted patents. Deployed 150+ perception-enabled AMRs across 30 warehouses.
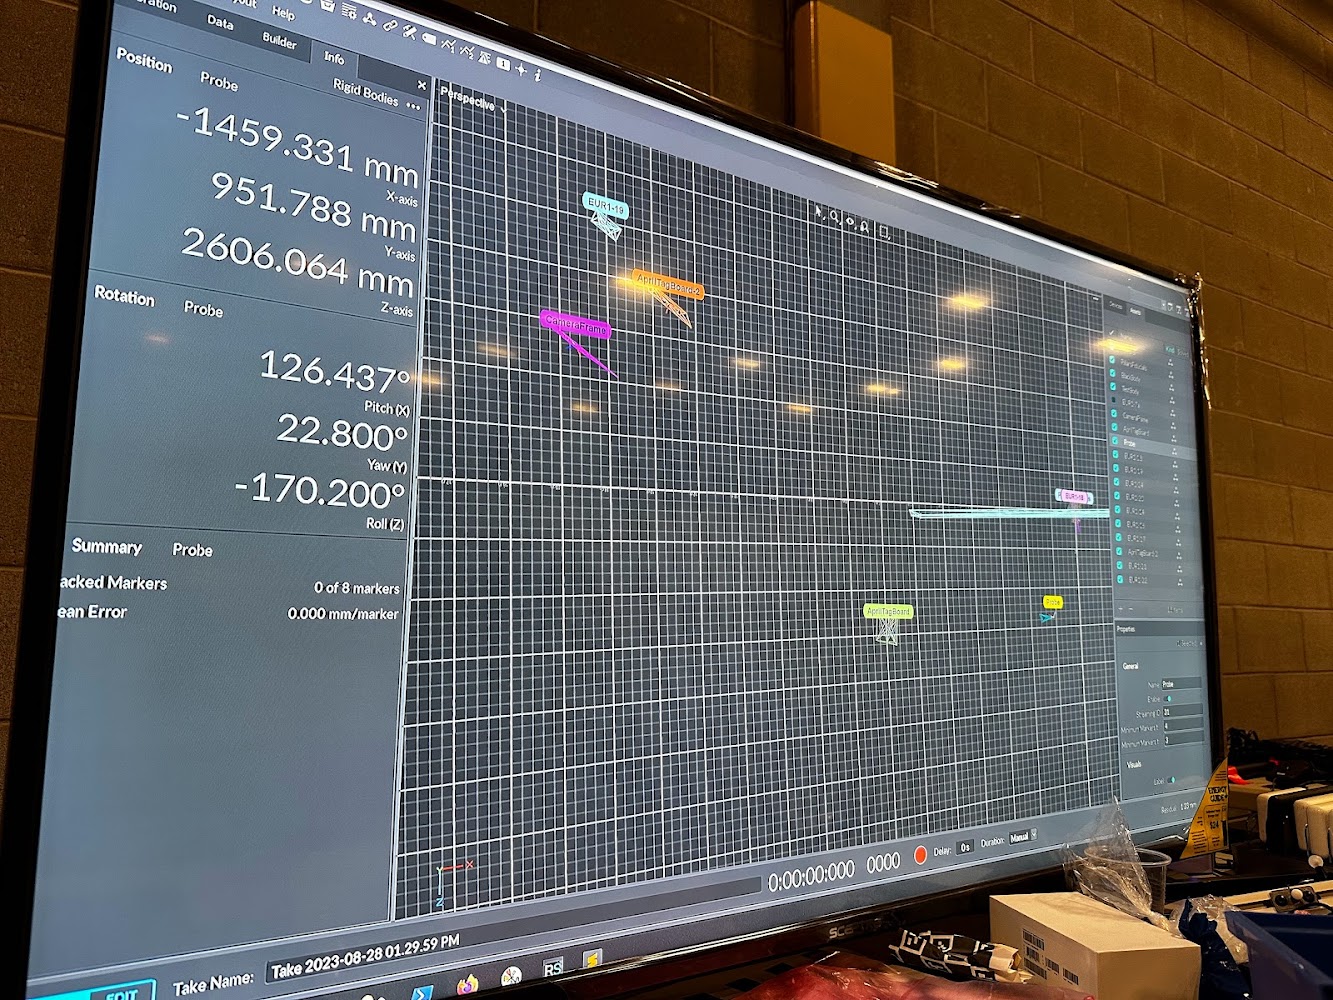
  • Established an OptiTrak motion-capture lab generating 1.5M+ training images, enabling the industry-first AI-perception AMR forklift (MiR1200 Pallet Jack) to seamlessly pick up shrink-wrapped or damaged pallets.

Simulation

  • Led a high-fidelity simulation initiative on Isaac Sim (URDF/USD models, collision meshes). Reduced sim-to-real divergence to <10% vs. measured Kalman-filter states by calibrating inertia, contact dynamics, drivetrain parameters, and 2D LiDAR + RGB noise models.
  • Pre-empted 20+ critical safety failures in pallet docking through software-in-the-loop (SIL) testing of perception algorithms.
  • Built cloud-native simulation batch-testing pipelines, broadening operational-design-domain coverage from 30 → 370 test scenarios per pallet and cutting testing time by 95% vs. manual testing.

Embedded

  • Delivered the industry-first fully autonomous high-bay forklift (AutoGuide Max-N HighBay) with a Vision Processing Unit on NVIDIA Jetson Xavier, streaming real-time 6-DoF pallet pose estimates for visual servoing during fork insertion at rack heights up to 36 ft.

Cloud, Data & MLOps

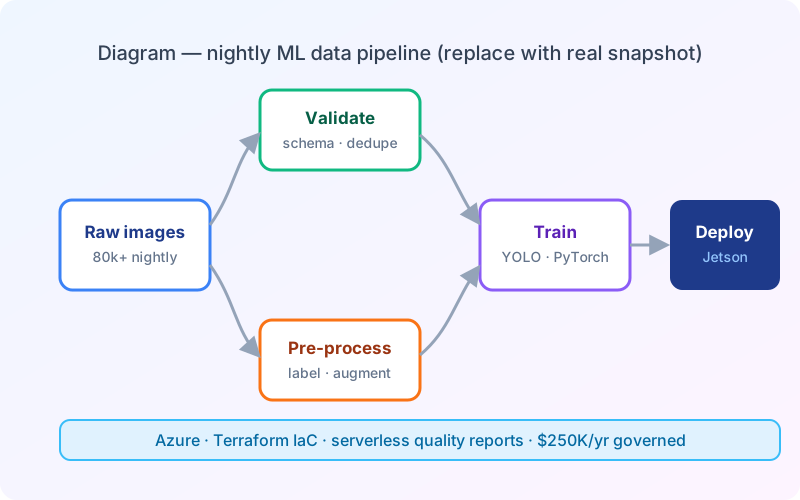
  • Built data ingestion & pre-processing pipelines transforming 80k+ raw images nightly into trainable datasets, with automated integrity checks, schema validation, de-duplication, cloud uploads, and serverless data-quality reporting.
  • Accelerated new pallet onboarding by 66% (3 weeks → 7 days), unlocking time-sensitive customer segments and generating $12M in new revenue.
  • Led the org-wide move to Terraform Infrastructure-as-Code on Azure: authored 18 modules adopted by ML, Data, and Simulation teams governing $250K/yr in cloud spend; reduced post-migration spend by $120K/yr (~48%).
  • C++17
  • Python
  • Isaac Sim
  • PyTorch
  • YOLO
  • Jetson Xavier
  • Azure
  • Terraform

Controls Engineer

AutoGuide Mobile Robots — North Reading, MA

Nov 2019 – Feb 2021
  • Developed motion-control and state-estimation software for autonomous mobile robots, including Kalman-filter-based localization and drivetrain control.
  • Collaborated across embedded, perception, and systems teams to bring AMR products from prototype to field deployment. [Add specific controls achievements — e.g., trajectory tracking metrics, CAN bus work]
  • C++
  • Kalman Filtering
  • CAN Bus
  • State Estimation

Software Lead (Volunteer) — Autonomous Underwater Vehicle

Robots in Service of the Environment (RISE) · partnered with World Wildlife Fund — Bedford, MA

Aug 2021 – Feb 2025
  • Spearheaded a team of 8 volunteer engineers building an in-house control and perception stack for an unmanned underwater vehicle targeting invasive lionfish.
  • Co-led field expeditions off Pensacola and West Palm Beach. Captured the first-ever lionfish taken autonomously by a robot — featured on PBS NewsHour, IEEE, and numerous other media. (Guardian LF1)
  • Architected a ROS 2 stack on Ubuntu Server: hardware abstraction layer, state-space control, NTP sync, autonomy modes, and heartbeat/failsafe mechanisms — replacing the legacy UUV control unit. Built a Qt-based UI with live sensor gauges, camera feeds with fish-tracking overlays, operating modes, and diagnostics.
  • Trained and optimized lionfish detection models — 0.88 precision (mAP 50-95) on YOLOv7 — integrated with DeepSORT multi-object tracking; curated a 20k+ image dataset; implemented autonomous target-seek mode.
  • ROS 2
  • Qt
  • YOLOv7
  • DeepSORT
  • Ubuntu Server

Planned Career Break — International Travel

Now returning to full-time robotics engineering roles

Nov 2025 – Sep 2026

Extended international travel and personal commitments. Actively seeking senior perception / simulation / robotics software roles.

03 Featured Projects

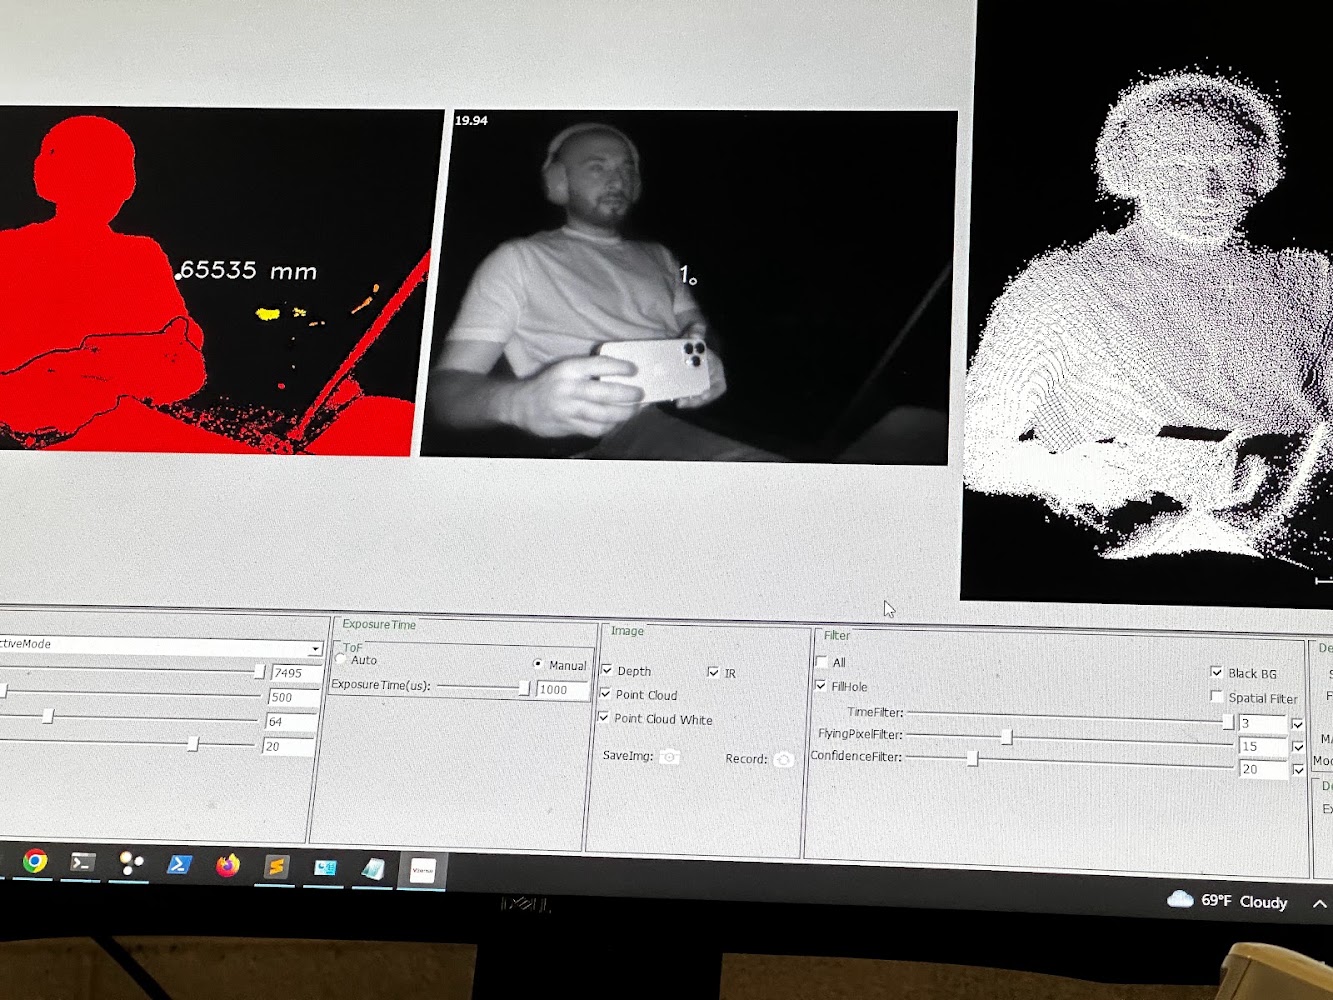
Intel RealSense viewer showing depth, infrared, and point-cloud streams of a person

6-DoF Pallet Pose Detection

Patented

Three generations of pallet pose estimation — 2D LiDAR geometry, 3D ToF point clouds, and RGB ML models — trained on 1.5M+ OptiTrak motion-capture images. Powers the MiR1200 Pallet Jack's ability to handle shrink-wrapped and damaged pallets. 150+ robots in the field.

  • C++17
  • PCL
  • OpenCV
  • 2D/3D LiDAR
  • ToF
  • YOLO
Illustration of an Isaac Sim warehouse environment with an AMR and planned trajectory

High-Fidelity Simulation & SIL Testing

Featured

Isaac Sim-based digital twin of warehouse operations: URDF/USD assets, calibrated inertia, contact dynamics, and sensor noise models achieving <10% sim-to-real divergence. Cloud batch-testing grew coverage from 30 to 370 scenarios per pallet and cut test time by 95%.

  • Isaac Sim
  • USD
  • URDF
  • Python
  • Azure
[Add case-study link]
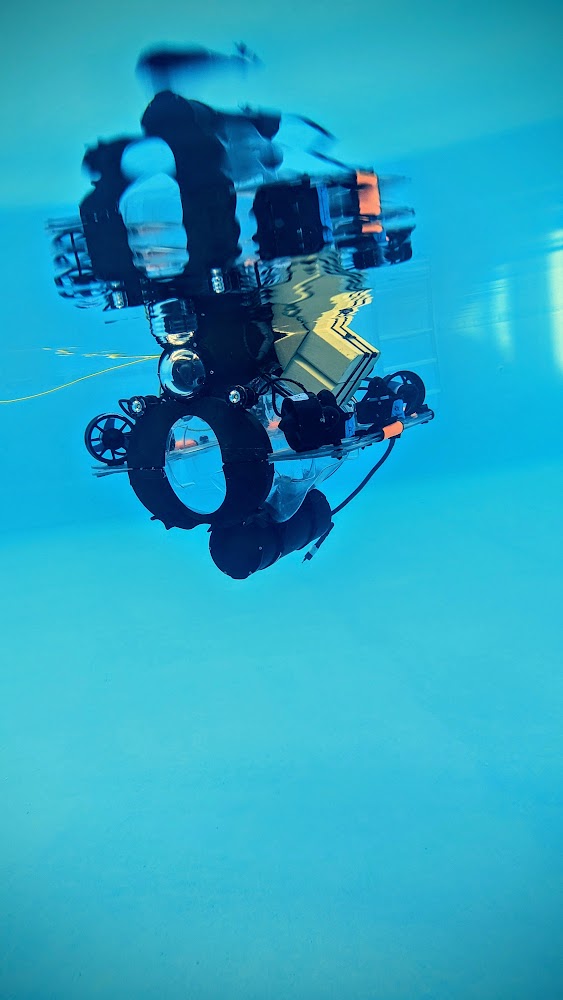
The Guardian LF1 autonomous underwater vehicle submerged in a test tank

Guardian LF1 — Lionfish Hunter UUV

Non-profit

Volunteer software lead for the first robot to autonomously capture an invasive lionfish — featured on PBS NewsHour and IEEE. Full ROS 2 stack, Qt operator UI with live tracking overlays, YOLOv7 + DeepSORT perception (0.88 mAP), and autonomous target-seek mode.

  • ROS 2
  • Qt
  • YOLOv7
  • DeepSORT
  • State-space control
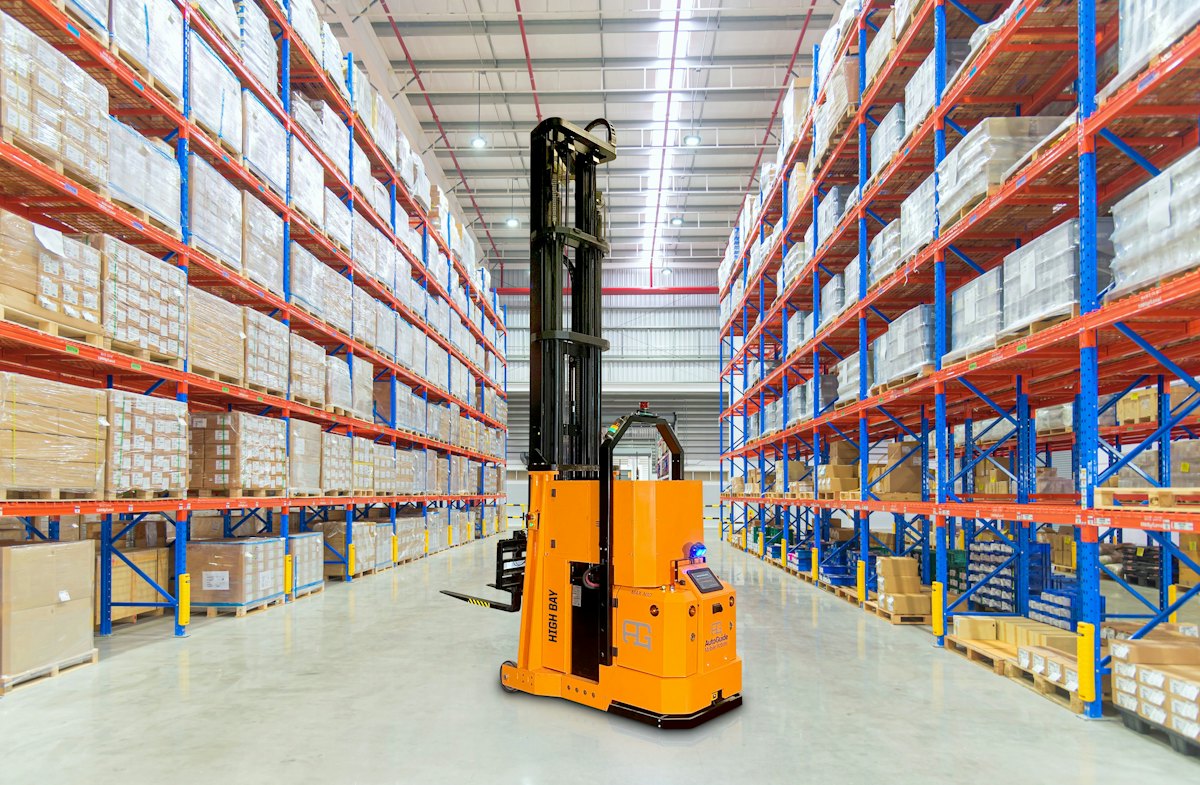
AutoGuide Max-N High Bay autonomous forklift operating in a high bay warehouse aisle

Max-N HighBay Autonomous Forklift

Embedded

Industry-first fully autonomous high-bay forklift. A Jetson Xavier-based Vision Processing Unit streams real-time 6-DoF pallet pose estimates for visual servoing during fork insertion at rack heights up to 36 ft — GMSL2 camera links, hardened for production.

  • Jetson Xavier
  • GMSL2
  • C++17
  • Visual servoing
  • CAN Bus
Diagram of a nightly ML data pipeline: ingestion, validation, training, and deployment

ML Data Pipeline & Azure IaC

MLOps

Nightly pipelines turning 80k+ raw images into trainable datasets with automated integrity checks and serverless quality reporting. Led the Terraform foundation for Azure — 18 modules governing $250K/yr spend, cut by ~48% post-migration. Pallet onboarding: 3 weeks → 7 days.

  • Azure
  • Terraform
  • Python
  • Serverless
  • MLOps
[Add architecture write-up link]

Open-Source & Side Projects

Space reserved for personal robotics projects, open-source contributions, or write-ups. [Add GitHub repos when ready]

  • ROS
  • MoveIt!
  • gRPC
  • IceOryx

★ Press Spotlight — Max-N High Bay

AutoGuide Max-N High Bay, the industry's first fully autonomous robotic high bay forklift, in a high bay warehouse
AutoGuide Max-N High Bay — the industry's first fully autonomous robotic high bay forklift. Photo: AutoGuide Mobile Robots via Supply & Demand Chain Executive.

On September 9, 2020, AutoGuide announced the MAX-N High Bay on Business Wire — carried by third-party trade media as the industry's first fully autonomous robotic high bay forklift. I delivered the on-board perception that makes it possible: a Jetson Xavier VPU streaming real-time 6-DoF pallet pose for visual servoing up to 36 ft, with smart pallet and rack detection sensors for precision picking.

  • 36 ftmax lift height
  • 2,400 lbpayload
  • 4 mphtravel speed
  • Weeksto install, no new racking

“AutoGuide Mobile Robots today announced the industry’s first fully autonomous mobile robot designed to automate racking and picking operations at high bay warehouses. The new AutoGuide MAX-N High Bay is an autonomous counterbalanced forklift that can travel up to 4 mph and lift 2,400-pound payloads up to 36 feet high.”

— Business Wire press release, Chelmsford, Mass., Sep 9, 2020

“Traditional high bay operations can be complex and potentially dangerous… Autonomous solutions like the MAX-N High Bay, on the other hand, increase efficiencies and keep both employees and products safe, providing an excellent return on investment in high bay environments.”

— Rob Sullivan, President & CEO, AutoGuide (Business Wire, Sep 2020)

04 Technical Skills

Languages & Middleware

  • C++17
  • Python
  • ROS / ROS 2
  • MoveIt!
  • Qt
  • IceOryx
  • gRPC

Perception & ML

  • OpenCV
  • PCL
  • 2D & 3D LiDAR
  • 3D ToF Cameras
  • PyTorch
  • TensorFlow
  • YOLO v7/v10
  • DeepSORT
  • VSLAM-Lab

Simulation & Test

  • NVIDIA Isaac Sim
  • USD
  • URDF
  • SIL Testing
  • Sim-to-Real Calibration
  • OptiTrak Motion Capture

Embedded & Hardware

  • NVIDIA AGX Orin / Xavier
  • GMSL2
  • CAN Bus
  • Real-time Systems
  • Sensor Calibration

Cloud & DevOps

  • Azure
  • Terraform (IaC)
  • Serverless Functions
  • Data Pipelines
  • MLOps

Domains

  • 6-DoF Pose Estimation
  • Visual Servoing
  • Kalman Filtering
  • Warehouse Automation
  • Autonomous Vehicles (AMR / UUV)
  • Functional Safety

05 Patents & Education

📜 Patents

  • US Patent 12,560,930 B2 — Identifying Transport Structures (granted 2026) · Co-inventor

    Pallet and transport-structure detection from 2D LiDAR scans for autonomous mobile robots.

  • US Patent 11,977,392 B2 — Identifying Elements in an Environment (granted 2024) · Co-inventor

    3D camera point-cloud processing for environment element identification in warehouse automation.

  • US Patent Application Pub. 2021/0347617 A1 — Engaging an Element · Co-inventor

🎓 Education

  • M.Eng., Robotics University of Maryland, College Park · 2017 – 2019
  • B.Sc., Mechatronics & Control University of Engineering and Technology, Lahore · 2011 – 2015

📰 Press

  • Business Wire (Sep 9, 2020) “AutoGuide Introduces the Industry’s First Fully Autonomous Robotic High Bay Forklift” — also carried by Supply & Demand Chain Executive
  • PBS NewsHour Guardian LF1 — first autonomous lionfish capture by a robot
  • IEEE Coverage of the RISE / WWF lionfish-hunting UUV

06 Contact

Let's build robots together.

Open to senior robotics software roles in perception, simulation, or embedded autonomy — in Austin, TX or remote/relocation.

mjerrar28@live.com

⬇ Download résumé (PDF)